Zhexian* Li

zhexian[at]umich[dot]edu
I am a Schmidt AI in Science Postdoctoral Fellow at the Michigan Institute for Data and AI in Society, University of Michigan, Ann Arbor, working with Necmiye Ozay and Dimitra Panagou. Prior to that, I received a Ph.D. degree in civil engineering and an M.S. degree in electrical engineering at the University of Southern California, working with Ketan Savla, and received a B.Eng. degree in transportation engineering at Southeast University in Nanjing, China.
I work at the intersection of theoretical domains in control, optimization, and learning, and application domains in civil infrastructure and mobility systems. My research develops algorithms and tools for smart operations of infrastructure and mobility systems with provable guarantees in performance and resilience.
In my spare time, I enjoy spending time with my family and cycling around mountains and forests.
news
| Apr 08, 2026 | Informal seminar talk at the Center for Control, Dynamical Systems, and Computation, University of California, Santa Barbara. |
|---|---|
| Mar 23, 2026 | Invited talk at the Department of Decision and Control, KTH Royal Institute of Technology. |
| Jan 29, 2026 | Invited talk at the School of Science and Engineering, the Chinese University of Hong Kong, Shenzhen. |
| Dec 22, 2025 | Our paper “Output-feedback adaptive model predictive control for ramp metering: a set-membership approach” was provisionally accepted by Automatica. |
| Nov 03, 2025 | Our paper “A complex spatial frequency approach to optimal control of finite-extent linear evolution systems” was conditionally accepted by IEEE Transactions on Automatic Control. |
selected publications
- HMT
 Constrained bilinear optimal control of reactive evolution equationsInternational Journal of Heat and Mass Transfer, 2027
- CDC
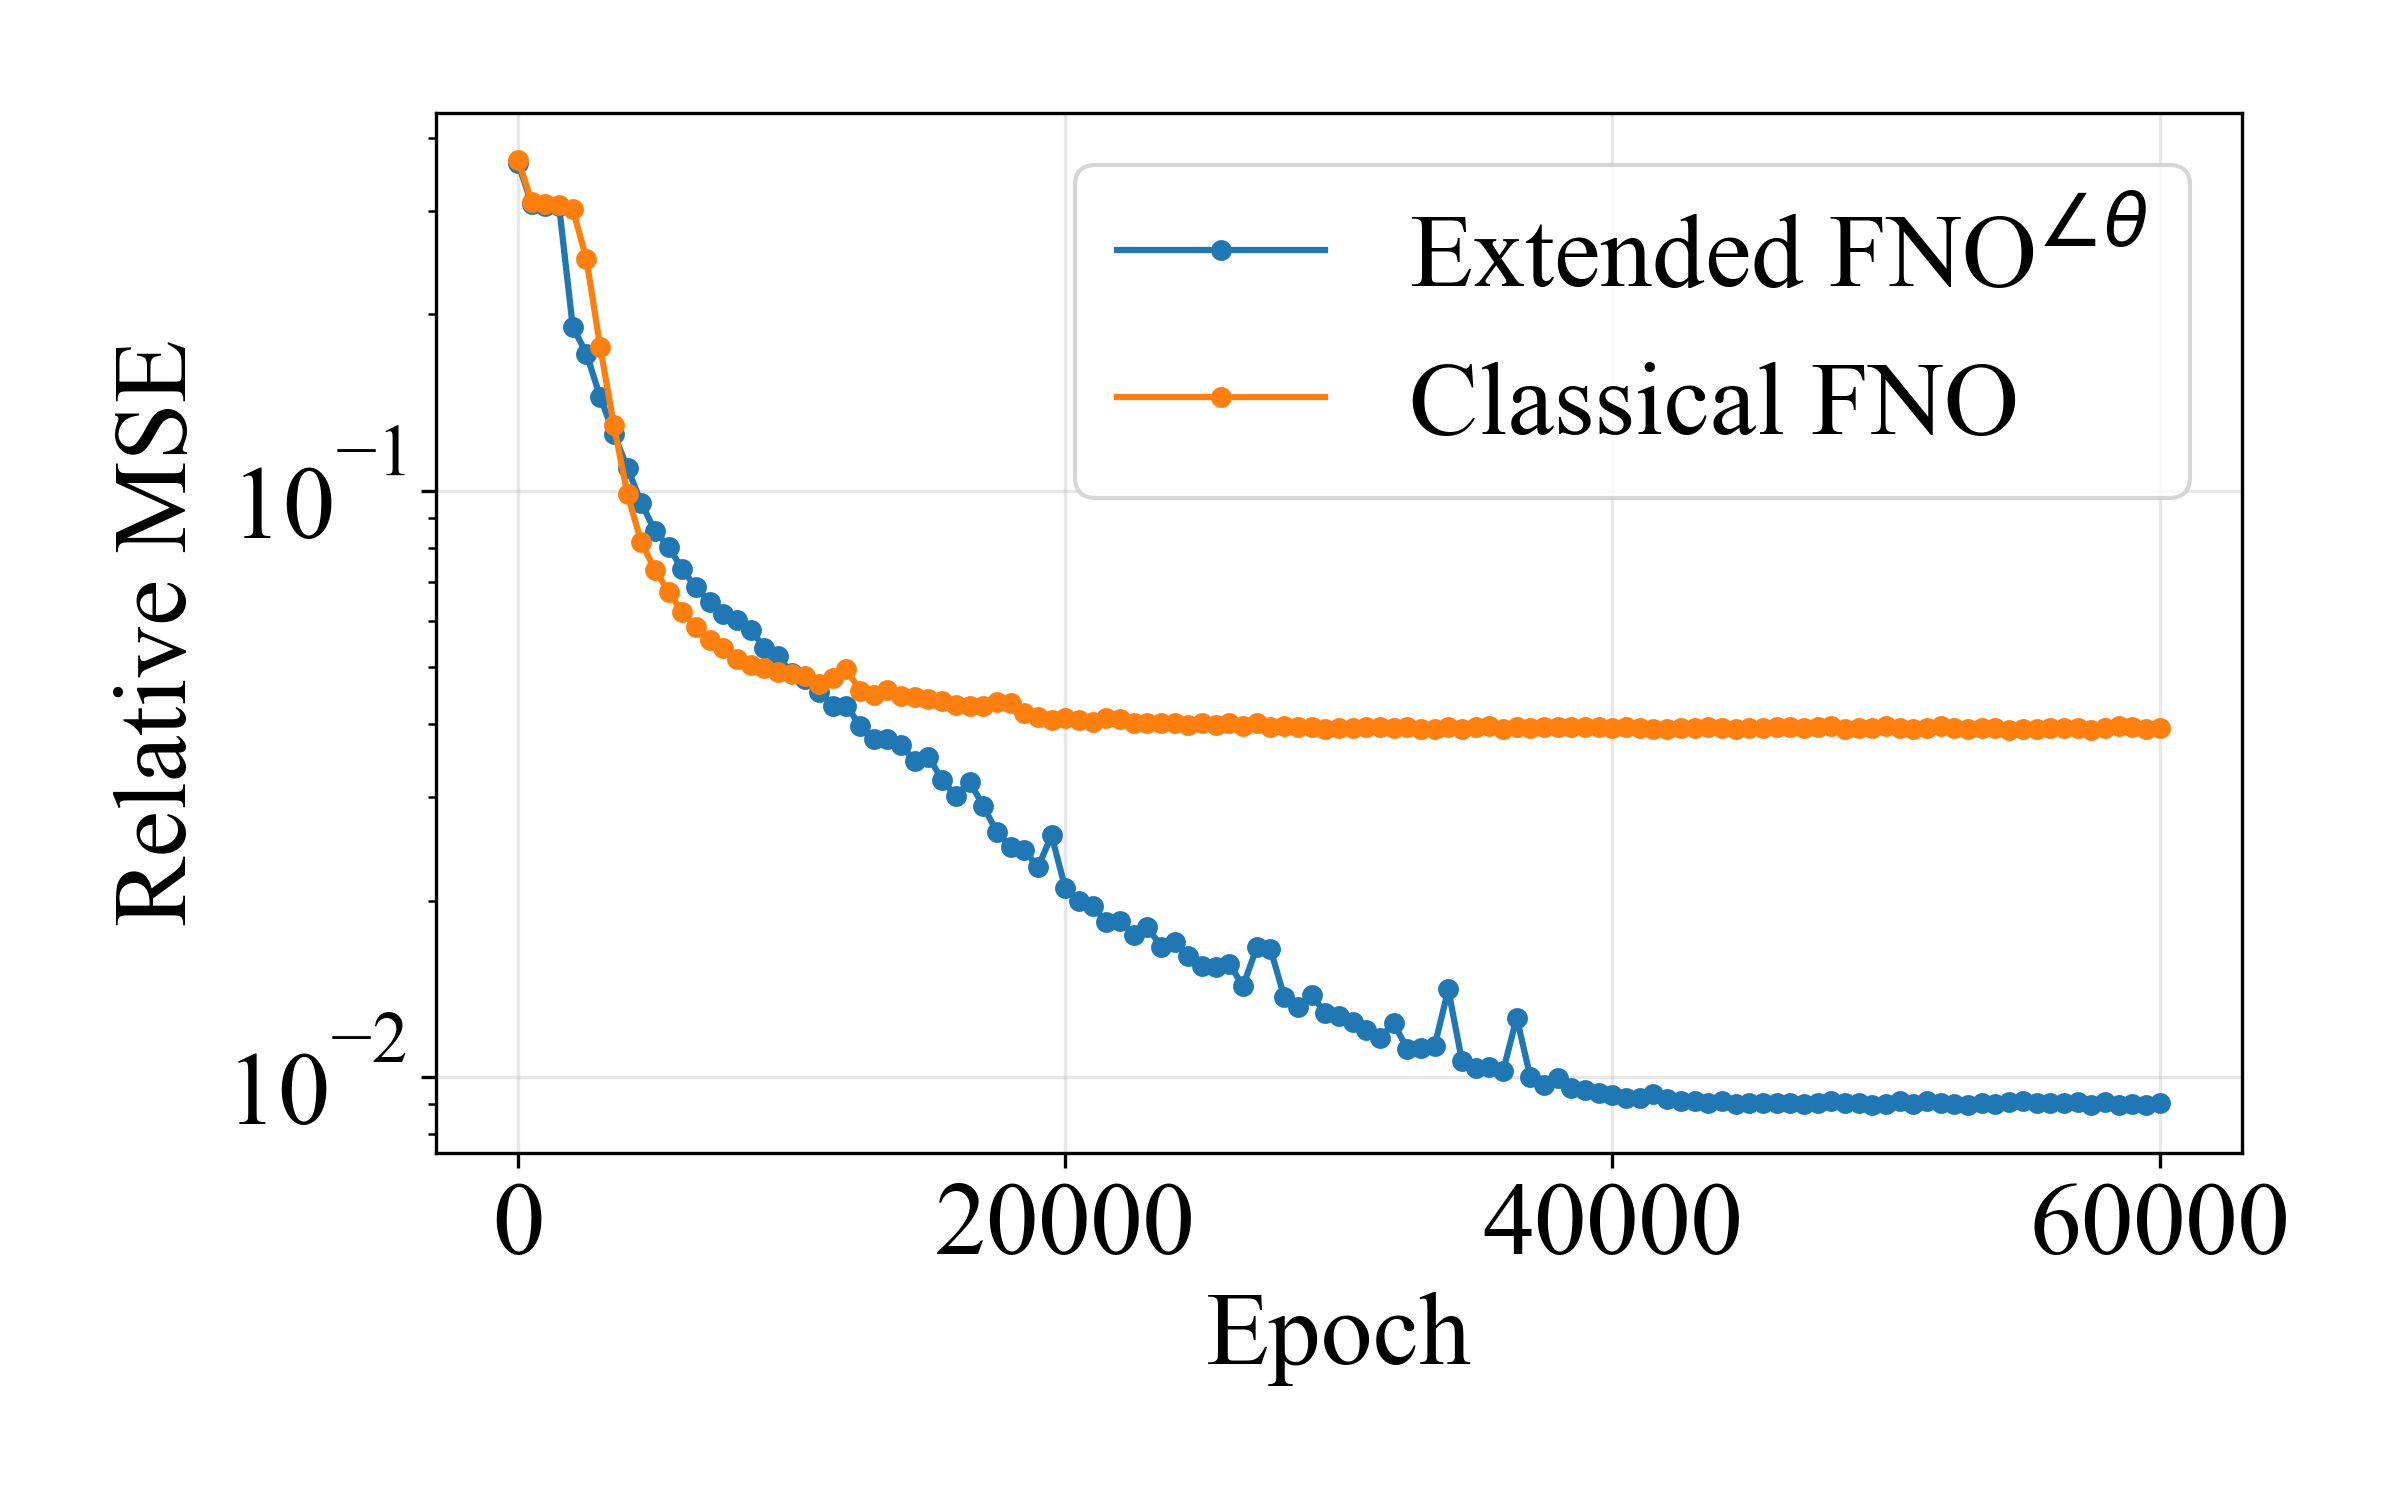 FNO^∠θ: Extended Fourier neural operator for learning state and optimal control of distributed parameter systemsIn 2026 IEEE Conference on Decision and Control (CDC), 2026
- TAC
 A complex spatial frequency approach to optimal control of finite-extent linear evolution systemsIEEE Transactions on Automatic Control, 2026
- Automatica
 Output-feedback adaptive model predictive control for ramp metering: a set-membership approachAutomatica, 2026